Roboto Origin
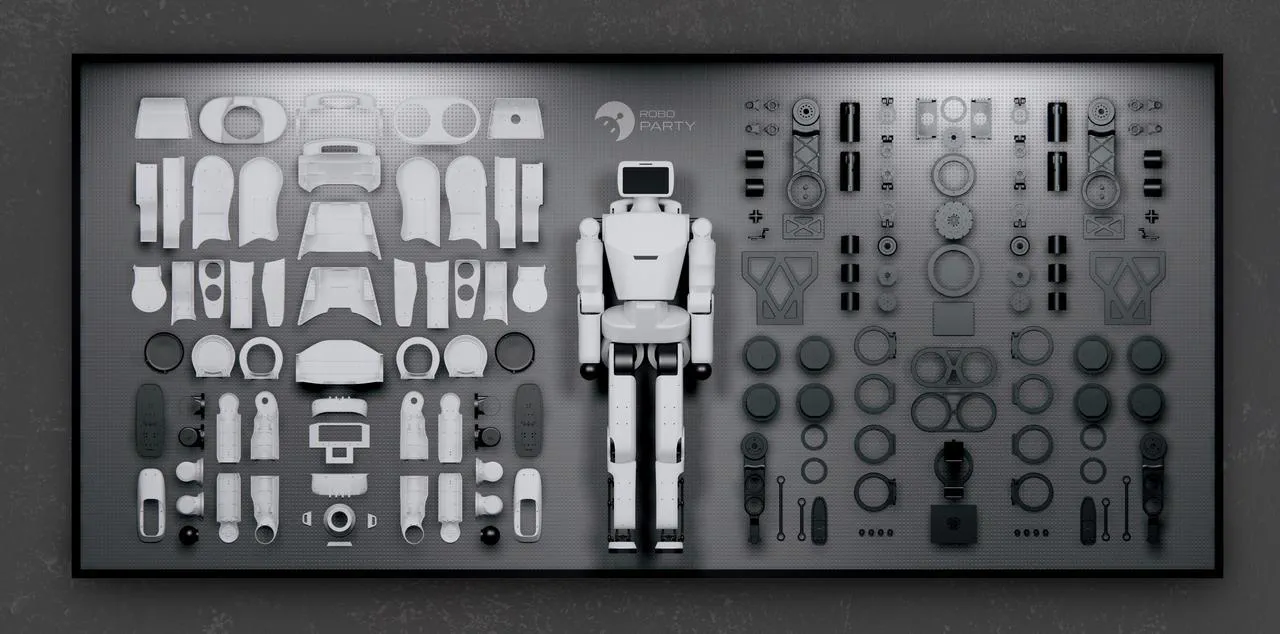
Source repository: Roboparty/roboto_origin
Original README: README.md
License: GPLv3
Overview#
ROBOTO_ORIGIN is a fully open-source DIY humanoid robot prototype from RoboParty. The project publishes the robot’s structure, electronics, training workflow, deployment stack, and related resources so developers can study, reproduce, and extend the platform.
The repository is an aggregation snapshot of several core sub-repositories. It gives users one entry point for pulling the project resources, while module-level issues and contributions should go to the relevant module repository.
Documentation#
Repository Modules#
| Module | Purpose |
|---|---|
| rpo_hardware | Mechanical structure, CAD drawings, PCB design, and BOM improvements. |
| roboparty_deploy | ROS2 deployment framework, middleware modules, deployment configs, IMU and motor integration. |
| roboparty_train | Isaac Lab reinforcement learning workflow, training environments, simulation configs, and Sim2Sim transfer. |
| rpo_description | URDF/MJCF kinematic and dynamic descriptions, plus visual and collision meshes. |
| roboparty_firmware | Embedded software, USB2CAN, OrangePi/RDK build tooling, and system daemon management. |
| rpo_appearance | Exterior shell design assets and prototype enclosure documentation. |
| roboparty_navigation | Navigation and localization application modules for RPO experiments. |
| roboparty_xr_teleop | XR teleoperation application for RPO experiments. |
Quick Start#
git clone https://github.com/Roboparty/roboto_origin.git
cd roboto_origin
git pull
After cloning, enter each modules/... directory and follow the README for that module.
Community#
- QQ Group:
546376843
Notes#
The project README states that basic Linux and ROS2 knowledge is helpful, but the documentation is intended to be beginner-friendly. For safety and licensing details, read the original repository’s disclaimer and GPLv3 license before operating real robot hardware.